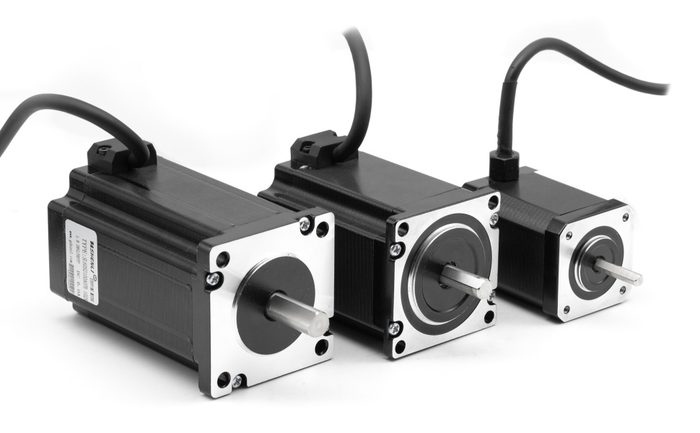
Stepper Motors
NEMA-frame steppers, geared steppers and driver modules.
Also searched as: nema 17nema 23stepper driverstepper motor
-
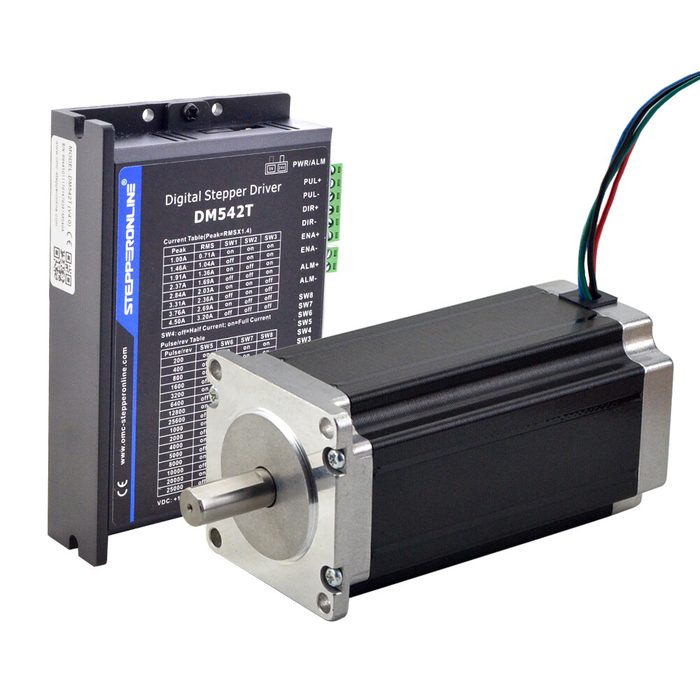
DM542T Stepper Motor Driver
Current: 1.0-4.2ANEMA Frame Compatibility: Nema 17, Nema 23Voltage: 20-50VDC
AliExpressWholesale price quotes available Request a quote -
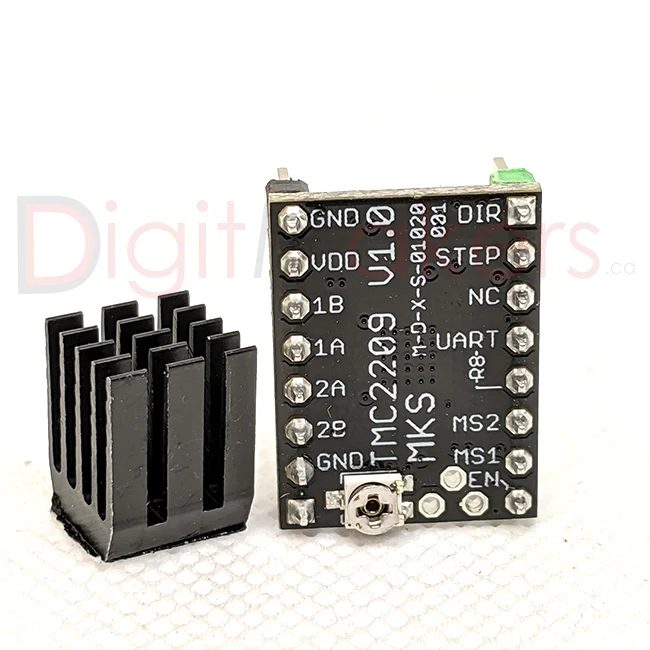
MKS TMC2209 Stepper Driver
Dimensions: 16 x 13 x 3 cmNEMA Frame Compatibility: Nema 17Weight: 0.060 kg
AliExpressWholesale price quotes available Request a quote -
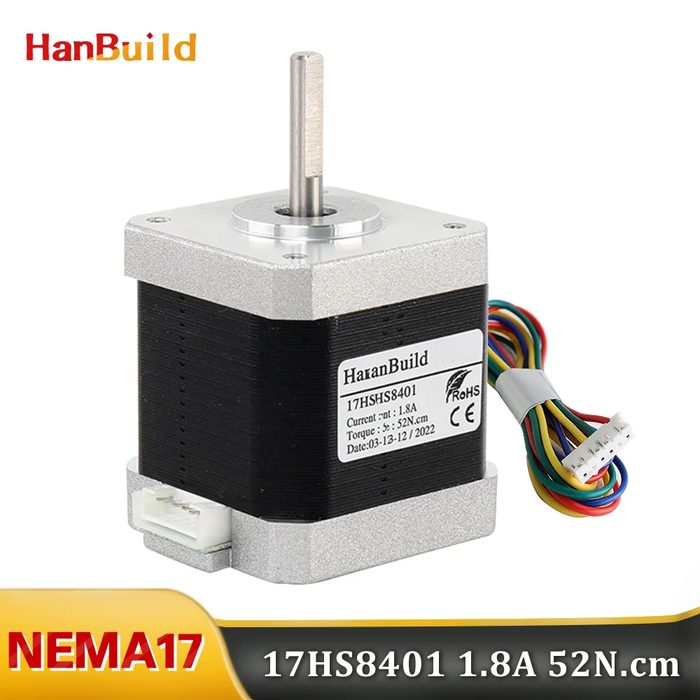
NEMA 17 Hybrid Stepper Motor (Dual shaft)
Holding Torque: 78 oz-in
AliExpressWholesale price quotes available Request a quote -
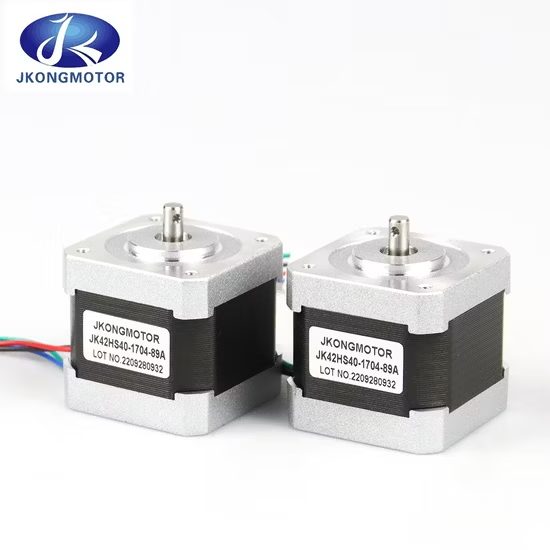
Nema 17 Hybrid Stepper Motor 0.7N 1.5A 4-lead
Current: 1.5 AHolding Torque: 0.7 NStep Angle: 1.8 degrees
AliExpressWholesale price quotes available Request a quote -
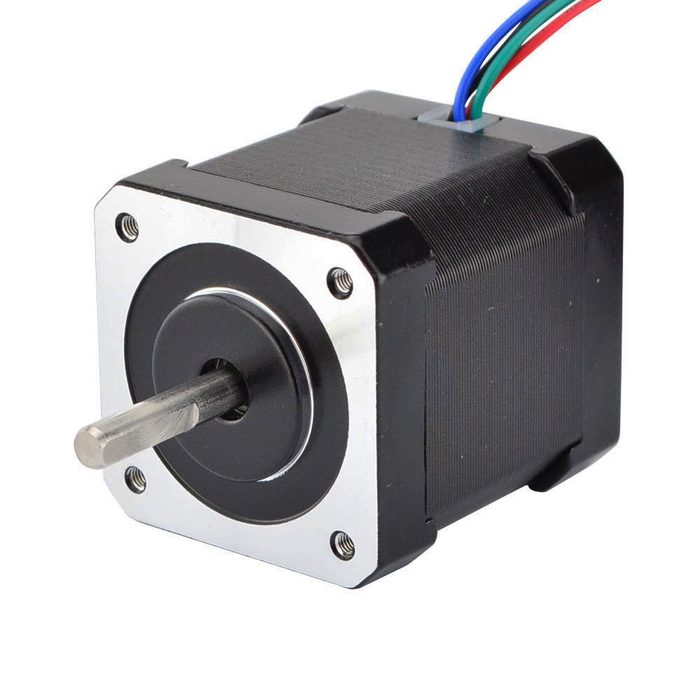
Nema 17 Stepper Motor
Current: 0.4AHolding Torque: 26 NcmLeads: 4Step Angle: 1.8°Voltage: 12V
AliExpressWholesale price quotes available Request a quote -
Nema 17 Stepper Motor
Current: 2AHolding Torque: 59 NcmStep Angle: 1.8°
AliExpressWholesale price quotes available Request a quote -
Nema 17 Stepper Motor
Current: 0.4AHolding Torque: 40 NcmLeads: 4Step Angle: 1.8°Voltage: 12V
AliExpressWholesale price quotes available Request a quote -
Nema 17 Stepper Motor
Current: 0.42AHolding Torque: 23 NcmLeads: 4Resistance: 16 ΩVoltage: 6.72V
AliExpressWholesale price quotes available Request a quote -
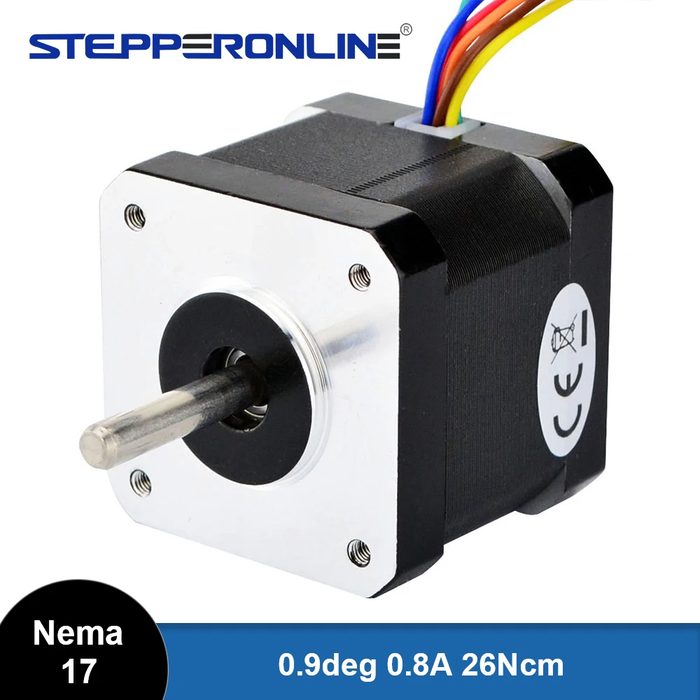
Nema 17 Stepper Motor 0.9deg
Cable Length: 1 mCurrent: 1.5 AFrame Size: 42x38 mmHolding Torque: 30 NcmShaft Diameter: 5 mm
AliExpressWholesale price quotes available Request a quote -
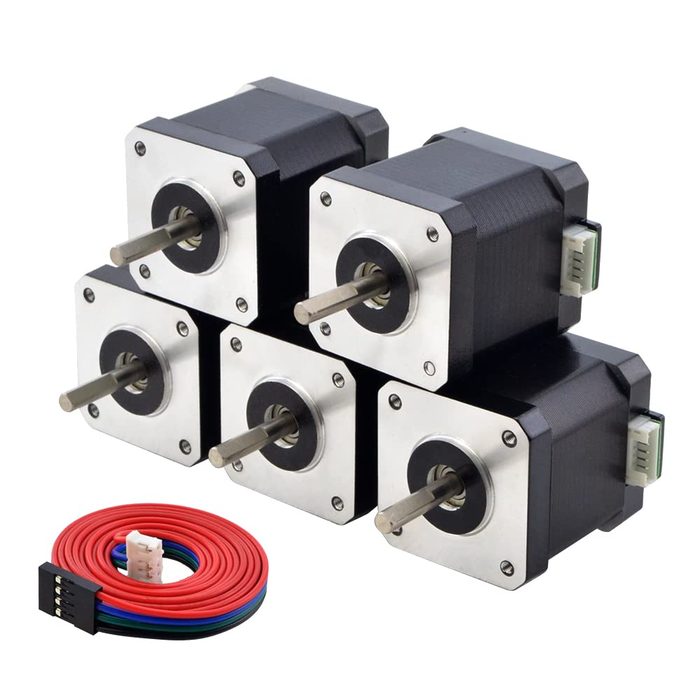
Nema 17 Stepper Motor 2A 1.8° 55Ncm
Current: 2 AHolding Torque: 55 NcmStep Angle: 1.8°
AliExpressWholesale price quotes available Request a quote -
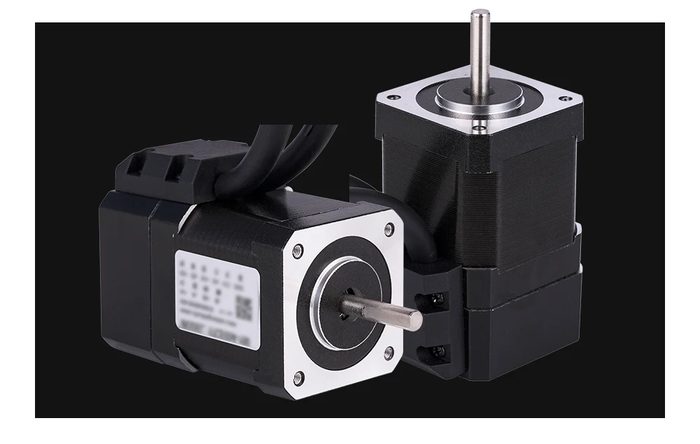
Nema 17 Stepper Motor Closed Loop
Current: 1.5AHolding Torque: 0.3 N.m
AliExpressWholesale price quotes available Request a quote -
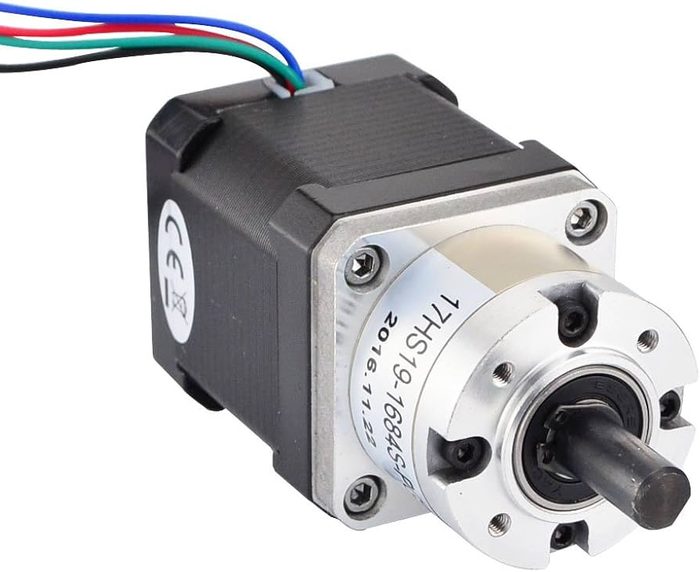
Nema 17 Stepper Motor with 5:1 Planetary Gearbox
Gear Ratio: 5.18:1Step Angle: 0.35°
AliExpressWholesale price quotes available Request a quote -
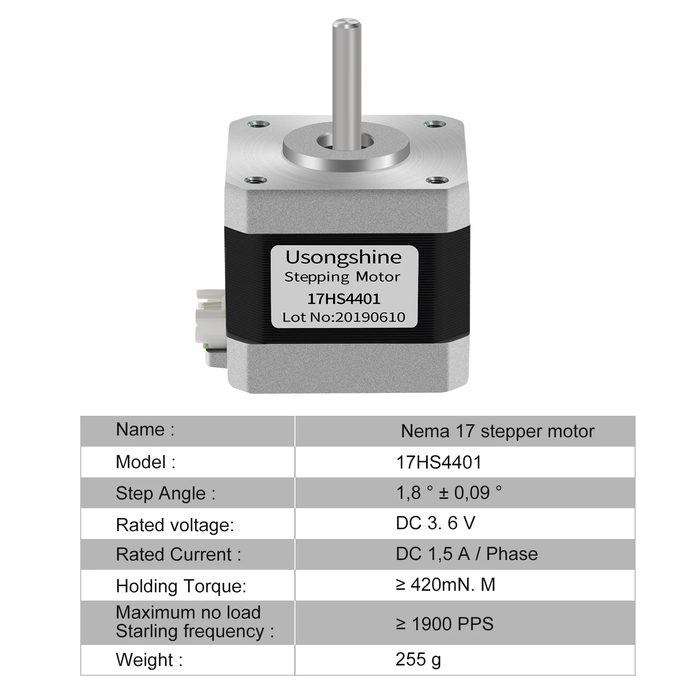
Nema 23 Hybrid Stepper Motor
Step Angle: 1.8 degrees
AliExpressWholesale price quotes available Request a quote -
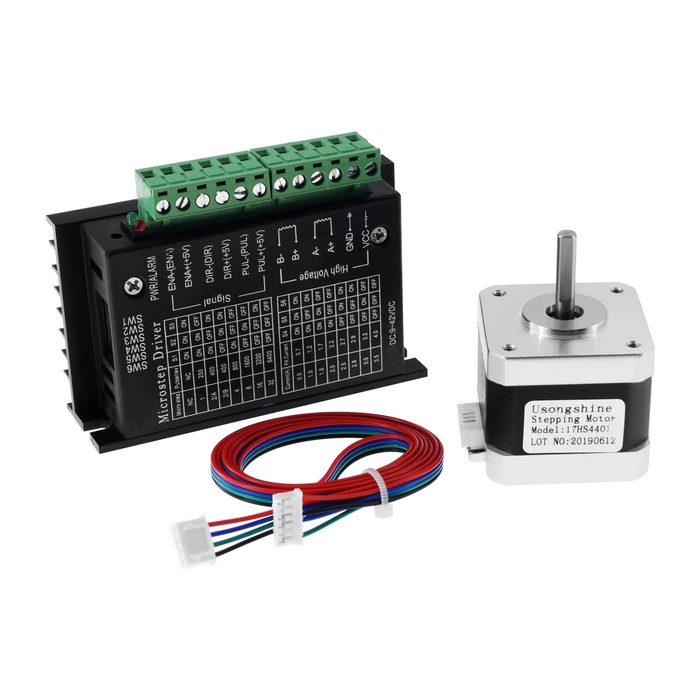
Stepper Motor Driver
Compatible NEMA Frame: 17, 23, 34Dimensions: 15 x 20 x 10 cmWeight: 0.600 kg
AliExpressWholesale price quotes available Request a quote -
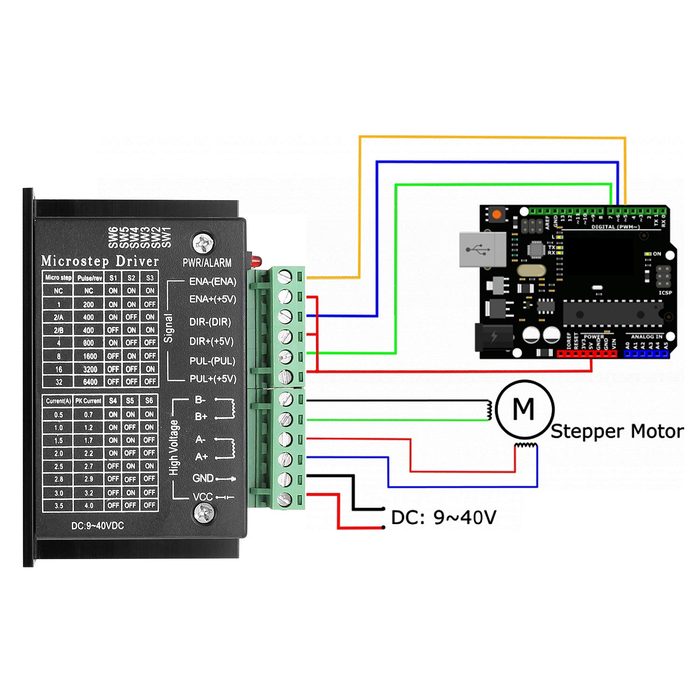
TB6600 Stepper Motor Driver
Current: 4.0AMicrostepping: 32 segmentsMotor Compatibility: 42, 57, 86Voltage: 42VDC
AliExpressWholesale price quotes available Request a quote -
 AliExpressWholesale price quotes available Request a quote
About stepper motors
Stepper motors are brushless DC electric motors that divide a full rotation into a number of discrete steps, allowing for precise position control without a feedback system. They are commonly used in applications requiring accurate positioning, such as 3D printers, CNC machines, and robotics. Key types include variable reluctance, permanent magnet, and hybrid synchronous steppers, with hybrid types offering a balance of torque, speed, and step resolution. Standardized NEMA frame sizes, such as NEMA 17, NEMA 23, and NEMA 34, define the motor's faceplate dimensions and mounting hole patterns, facilitating interchangeability. Performance is primarily characterized by holding torque, detent torque, step angle (e.g., 1.8 degrees or 0.9 degrees), rated current per phase, and winding resistance. Geared stepper motors integrate a planetary or spur gearbox to increase torque and resolution at the expense of speed. Stepper motor driver modules, often based on ICs like the A4988 or DRV8825, are essential for controlling the motor's current and step sequence, enabling microstepping for smoother operation and reduced resonance. Driver selection depends on motor current requirements, voltage, and desired microstepping capabilities. Motors typically feature steel laminations for the stator and rotor, with copper windings and often aluminum or steel end bells.
How to choose
When selecting a stepper motor, first determine the required holding torque to overcome static loads and the detent torque for unpowered stability. Next, identify the necessary step angle or microstepping resolution to meet positioning accuracy requirements for the application. Evaluate the available voltage and current capacity of the power supply and select a motor and driver combination that operates within these limits. Consider the operating speed range and select a motor that can maintain sufficient torque at the desired RPMs. Finally, choose a NEMA frame size that fits the mechanical constraints of the system, and if increased torque or finer resolution is needed, consider a geared stepper motor or a driver with microstepping capabilities.