Gripsters & Lifters
Mechanical, vacuum, magnetic and robotic gripsters plus end-of-arm tooling.
Also searched as: robot gripperparallel grippertwo jaw gripperthree jaw gripperangular gripperpneumatic gripperelectric grippervacuum grippersuction cupvacuum cupvacuum lifterventuri vacuum generator +45 more
-
 Made-in-ChinaWholesale price quotes available Request a quote
-
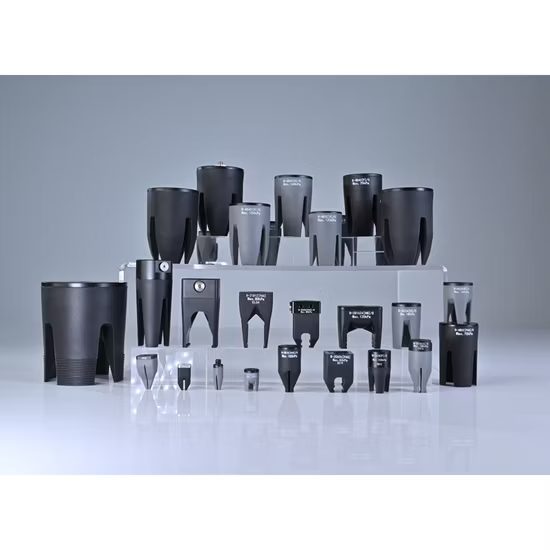
Bionic Soft Gripper for Automation Industry
Application: Automation IndustryType: Bionic
-
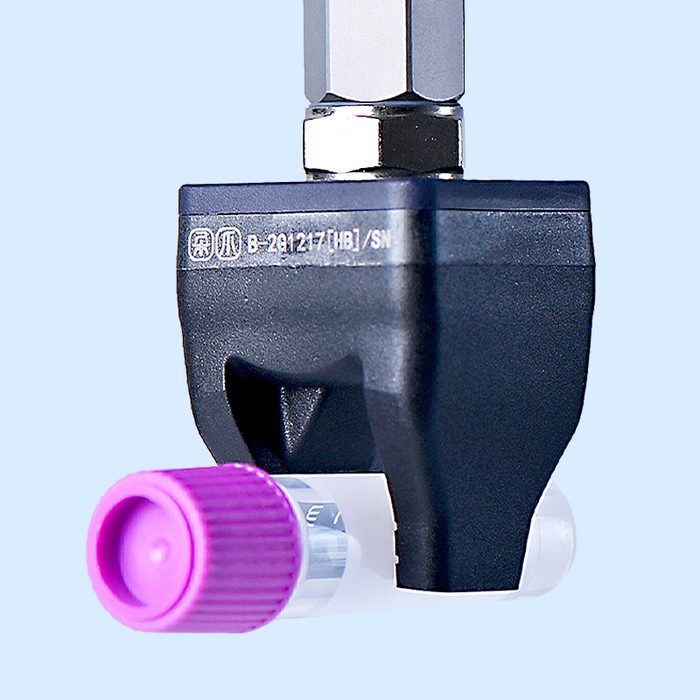
Compact Design Soft Gripper
Design: Compact
-
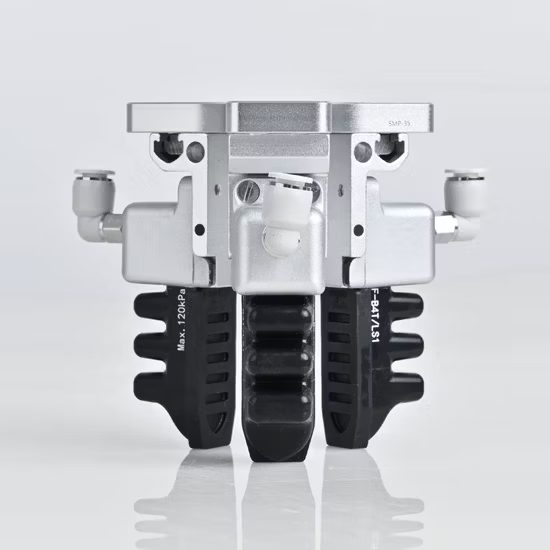
Customizable Soft Gripper with Anti-Slip Silicone Material
Anti-Slip: TrueFeature: Customizable
-
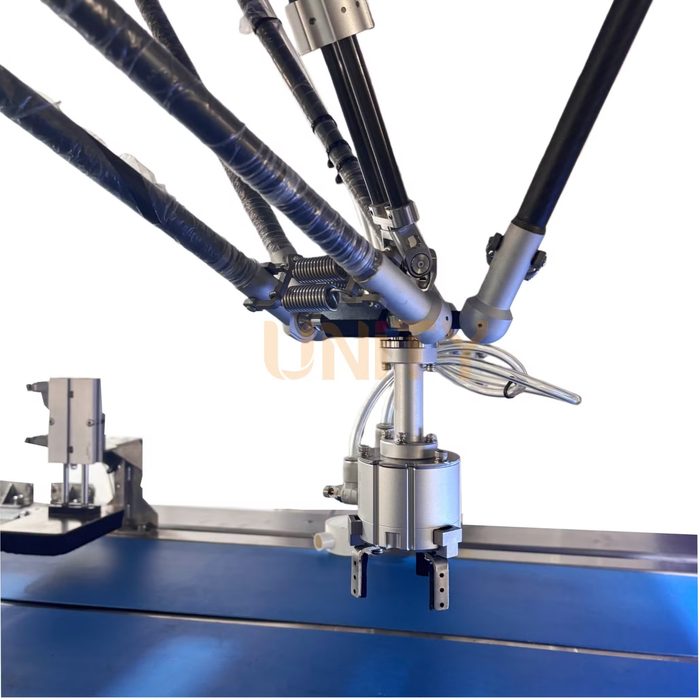
Delta Robot Gripper Junction Box
Drive Mode: ElectricOperation Mode: Automatic
-
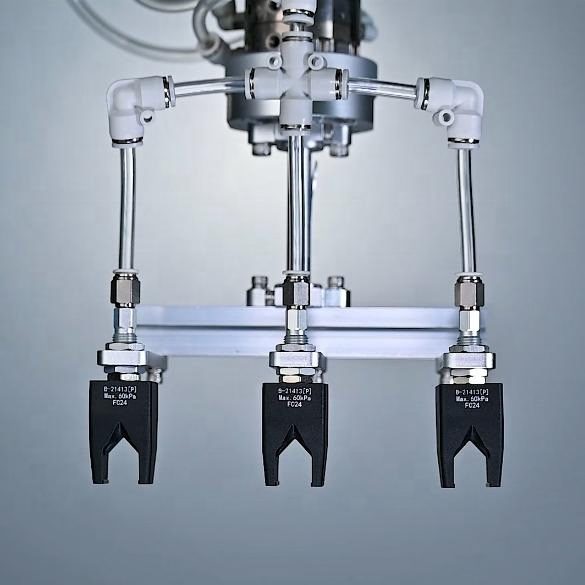
Electric Bicuspid Soft Miniature Claws
Actuation: ElectricSize: MiniatureType: Bicuspid
-
 Made-in-ChinaWholesale price quotes available Request a quote
-
 Made-in-ChinaWholesale price quotes available Request a quote
-
 Made-in-ChinaWholesale price quotes available Request a quote
-
High-Precision Pneumatic Soft Robotic Gripper
Precision: HighType: Soft
-
-
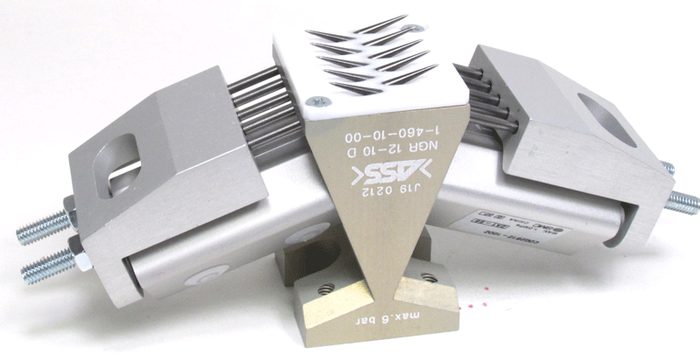 Made-in-ChinaWholesale price quotes available Request a quote
-
Made-in-ChinaWholesale price quotes available Request a quote
-
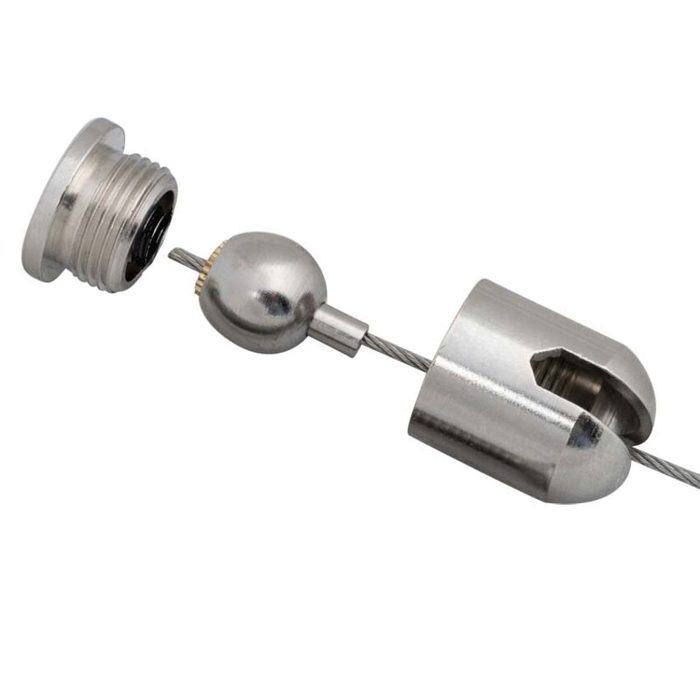
Plafondbevestigingskabelgripper
Cable Diameter: 1.5mm~2.0mm
Made-in-ChinaWholesale price quotes available Request a quote -
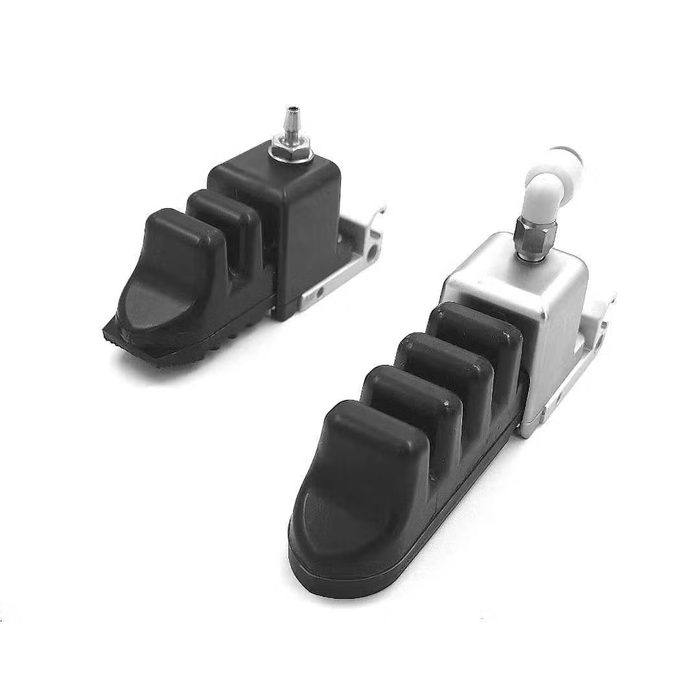
Pneumatic Cylinder Gripper Soft Beak
Actuation: PneumaticType: Cylinder
-
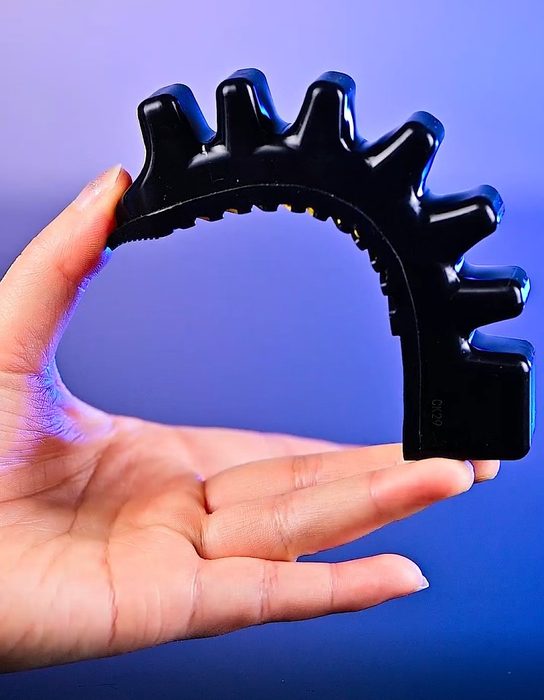
Pneumatic Finger Soft Gripper
Type: Soft
-
 Made-in-ChinaWholesale price quotes available Request a quote
-
 Made-in-ChinaWholesale price quotes available Request a quote
-
Made-in-ChinaWholesale price quotes available Request a quote
-
Pneumatic Soft Flexible Two Finger Suction Cub
Actuation: PneumaticFingers: 2Flexibility: Flexible
-
Pneumatic Soft Robotics Customization Gripper
Actuation: PneumaticFeature: Customization
-
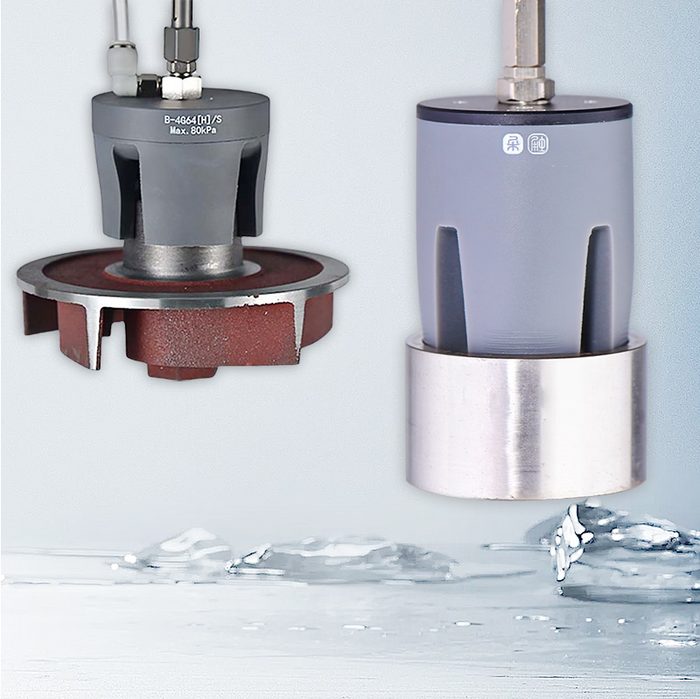
Pneumatic Two Fingers Soft Gripper
Actuation: PneumaticFingers: Two
-
-
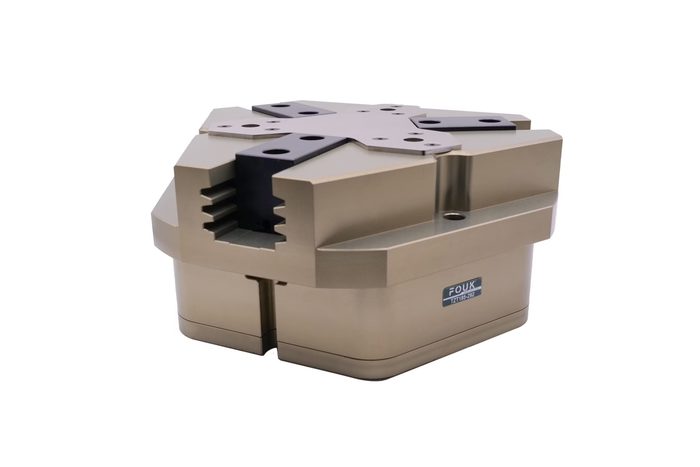
Robot Gripper 3-Fingers
Structure: Piston Cylinder
-
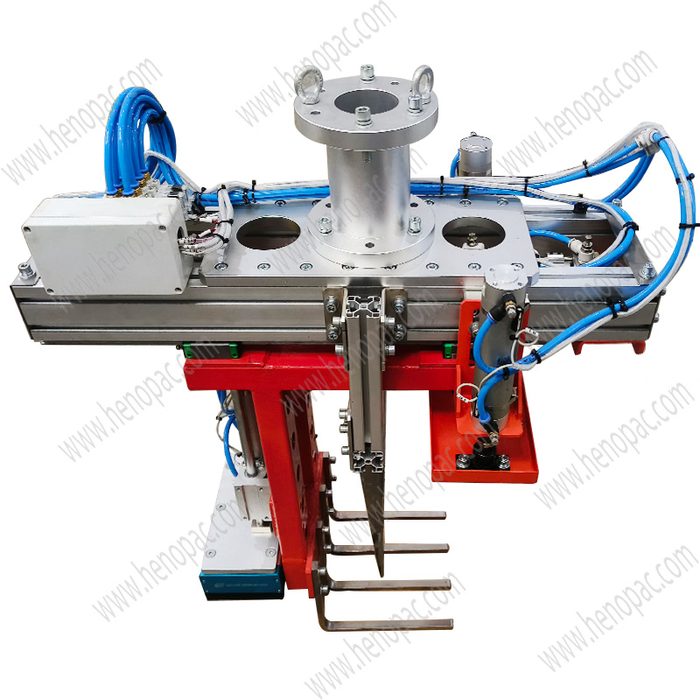
Robotic Carton Handling Gripper
Application: Carton Handling
-
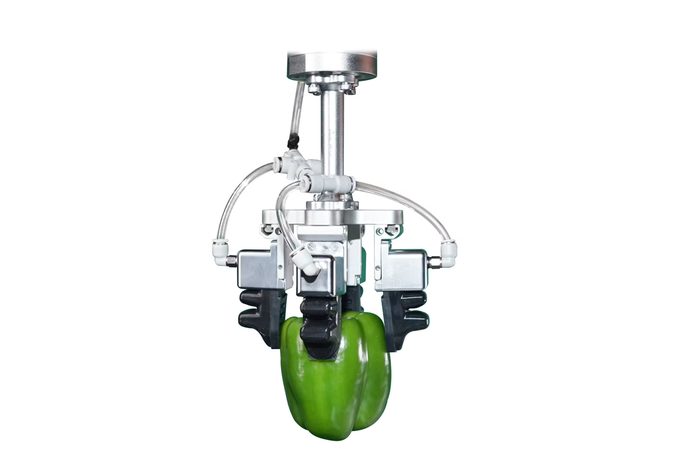
Robotic Gripper Electric 2 Fingers Parallel
Fingers: 2Type: Parallel
-
 Made-in-ChinaWholesale price quotes available Request a quote
-
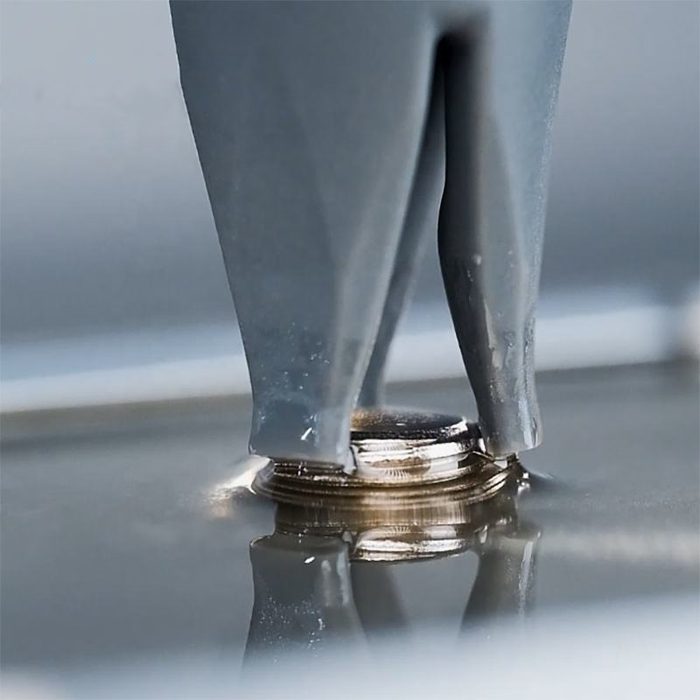
Soft Pneumatic 3D Printed Gripper Fingers
Actuation: PneumaticManufacturing: 3D Printed
About gripsters & lifters
Gripsters are end-of-arm tooling (EOAT) components designed to grasp and manipulate objects in automated systems. They are broadly categorized by their actuation method and gripping mechanism. Mechanical gripsters, including parallel (two-jaw, three-jaw) and angular types, utilize pneumatic or electric power to actuate jaws that physically clamp onto a workpiece. Key selection parameters include jaw stroke, gripping force (N), repeatability (mm), and jaw opening (mm). Vacuum gripsters employ suction cups or pads, often coupled with venturi vacuum generators or vacuum pumps, to lift non-porous materials. Critical specifications include cup diameter (mm), lifting capacity (kg), and material (e.g., NBR, silicone, polyurethane). Magnetic gripsters use permanent magnets or electromagnets to handle ferromagnetic parts, with holding force (N) and demagnetization time being crucial. Soft gripsters and adaptive gripsters conform to irregular shapes, often using compliant materials or underactuated designs. Collaborative robot (cobot) gripsters are designed for safe human-robot interaction, often incorporating force sensing and compliant surfaces. Common gripster materials include anodized aluminum, hardened steel for jaws, and various elastomers for suction cups.
How to choose
When selecting a gripster, first determine the workpiece characteristics: material, weight, dimensions, and rigidity. This dictates the primary gripping principle (mechanical, vacuum, magnetic, soft). Next, consider the application's required gripping force or lifting capacity (N/kg) and the necessary jaw stroke or cup diameter. Evaluate the available utilities: pneumatic pressure, electrical power (DC voltage, current), or if a purely mechanical solution is needed. Assess environmental factors such as temperature, dust, or moisture, which influence material selection (e.g., IP rating, food-grade materials). Finally, consider integration requirements, including robot flange compatibility (ISO 9409-1) and communication protocols (e.g., Modbus TCP, EtherNet/IP).